Icp registration
Iterative Closest Point aligns two point clouds. Shown as a before/after picture it
Result
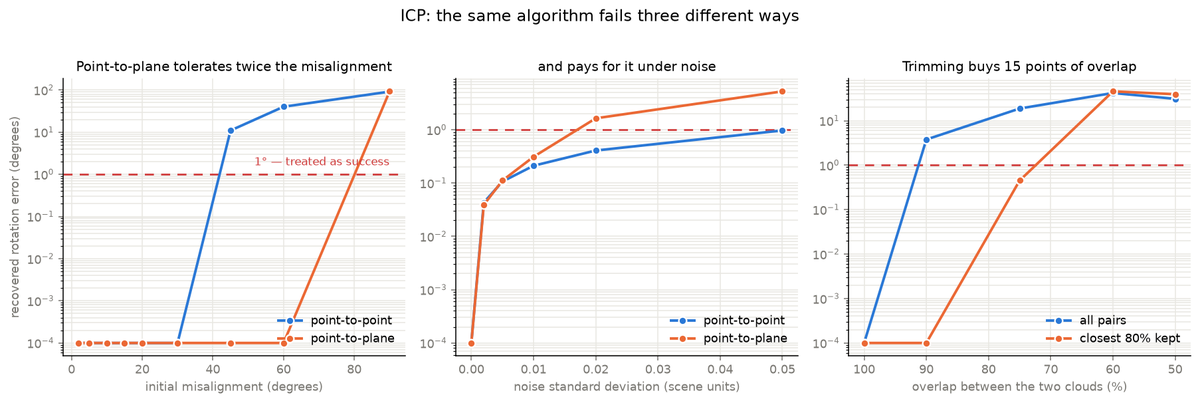
| shape | three fused blobs, 2,000 points — asymmetric, so rotation is unambiguous |
| ground truth | a known rigid transform; error is the geodesic angle to it |
| varied | initial misalignment, noise, overlap, trimming |
| success | recovered rotation within 1° |
The finding
Point-to-plane tolerates twice the misalignment
The convergence basin is 30° for point-to-point and 60° for point-to-plane — exactly double. Past its basin ICP does not fail loudly; it converges confidently to the wrong alignment, which is why a residual cannot be used to detect the failure.
Figures
Elsewhere
Code and full results on GitHub
Every number is read from the file the run produced. github.com/hammasbuilds · kaggle.com/muhammadhammas13