Wavelet denoising
[](https://www.python.org/)
Result
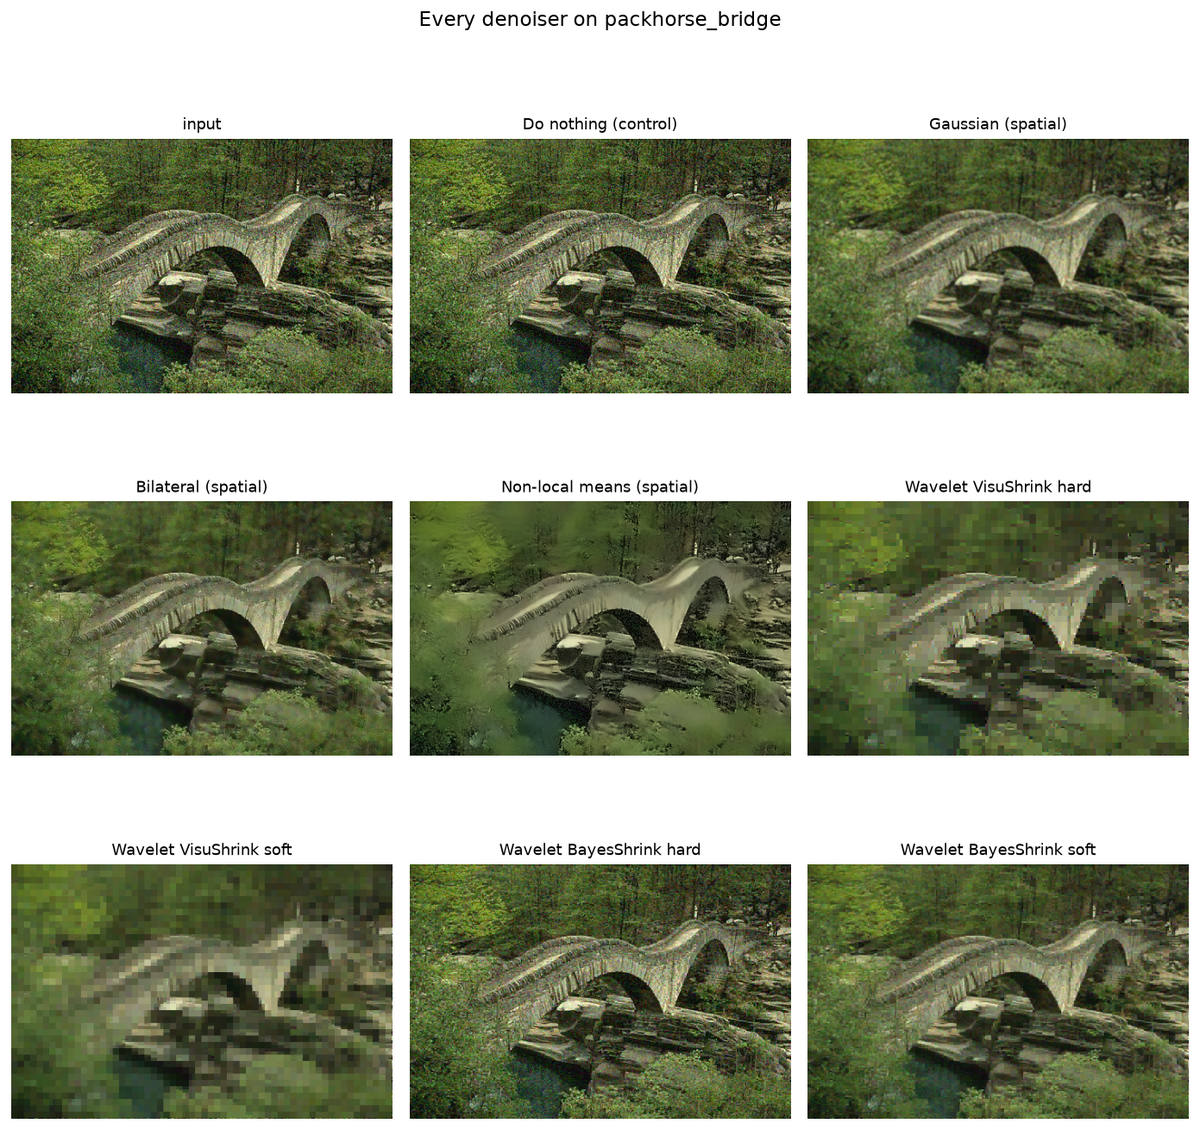
| Sr | Scene | Gaussian | **Bilateral** | VisuShrink soft | BayesShrink soft |
|---|---|---|---|---|---|
| 1 | black panther · sparsity 0.788 | 24.54 | **26.08** | 20.39 | 23.82 |
| 2 | warthogs drinking · sparsity 0.855 | 26.44 | **27.41** | 22.57 | 25.29 |
| 3 | cormorants nesting · sparsity 0.921 | 25.91 | **28.16** | 22.51 | 25.55 |
| 4 | taj mahal reflected · sparsity 0.947 | 25.52 | **28.15** | 22.19 | 25.63 |
The finding
The premise, measured before anything depends on it
The gap is real and large. A perfectly flat spectrum would put 0.10 in the top 10%; noise scores 0.44 because the largest samples of a Gaussian are still larger than the rest, and every photograph scores 0.69 or above. **Thresholding really can separate them.**
That is what makes the result interesting rather than disappointing: the method's justification is sound, and the Haar basis is still not a good enough one.
---
Figures
Elsewhere
Code and full results on GitHub (code private)
Every number is read from the file the run produced. github.com/hammasbuilds · kaggle.com/muhammadhammas13